

K Series Customizable Speed Reducer for Packaging Machinery
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
Explosion-Proof Motor K Series Speed Reducer
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
S97 SA97 Saf97 Sf97 Speed Reducer
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
H3hh8 Speed Reducer Budget Price
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
H4sh12 Speed Reducer with C5 Paint
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
RV Series Worm Gear Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
X (B) Series Planetary Cycloidal Pinwheel Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Nrv Speed Reducer for Car Wash System
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available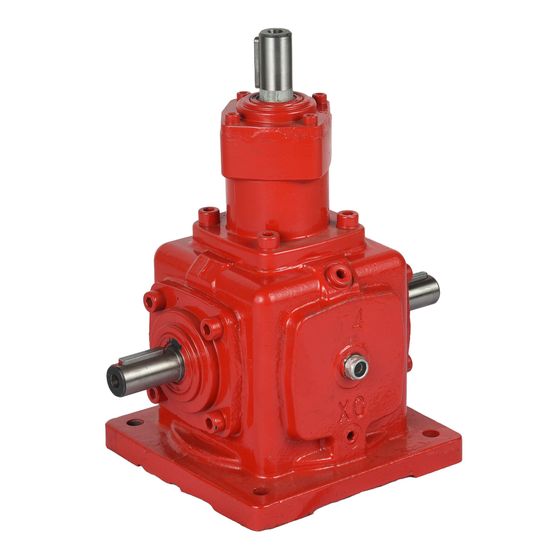
T Series Spiral Bevel Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Bevel Gear Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Worm Speed Reducer
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
Worm Gear Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Bkm Series Hypoid Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Food Grade Hypoid Speed Reducer for Food Processing
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Right Angle Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
Right Angle Hypoid Gear Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
K Series Speed Reducer High Efficiency
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
K Series Reducer with Customizable Speed
US$150.00-15,000.00
1 Set(MOQ)
Sample Available
Parallel Shaft Speed Reducer
US$150.00-15,000.00
1 Piece(MOQ)
Sample Available
F Series Gearbox Speed Reducer Gear Motor
US$150.00-15,000.00
1 Set(MOQ)
Sample Available


